 Adam Haroon
Control Safety · Aerial Autonomy
Urban Air Mobility
Safe, efficient, equitable traversal of multi-agent urban air vessels over a simulated Austin skyline.
Abstract
Urban air mobility promises fleets of autonomous vehicles sharing low-altitude airspace over cities. The research questions are safety questions: how do many agents traverse a skyline safely, efficiently, and equitably, and how do the guarantees hold as the fleet grows?
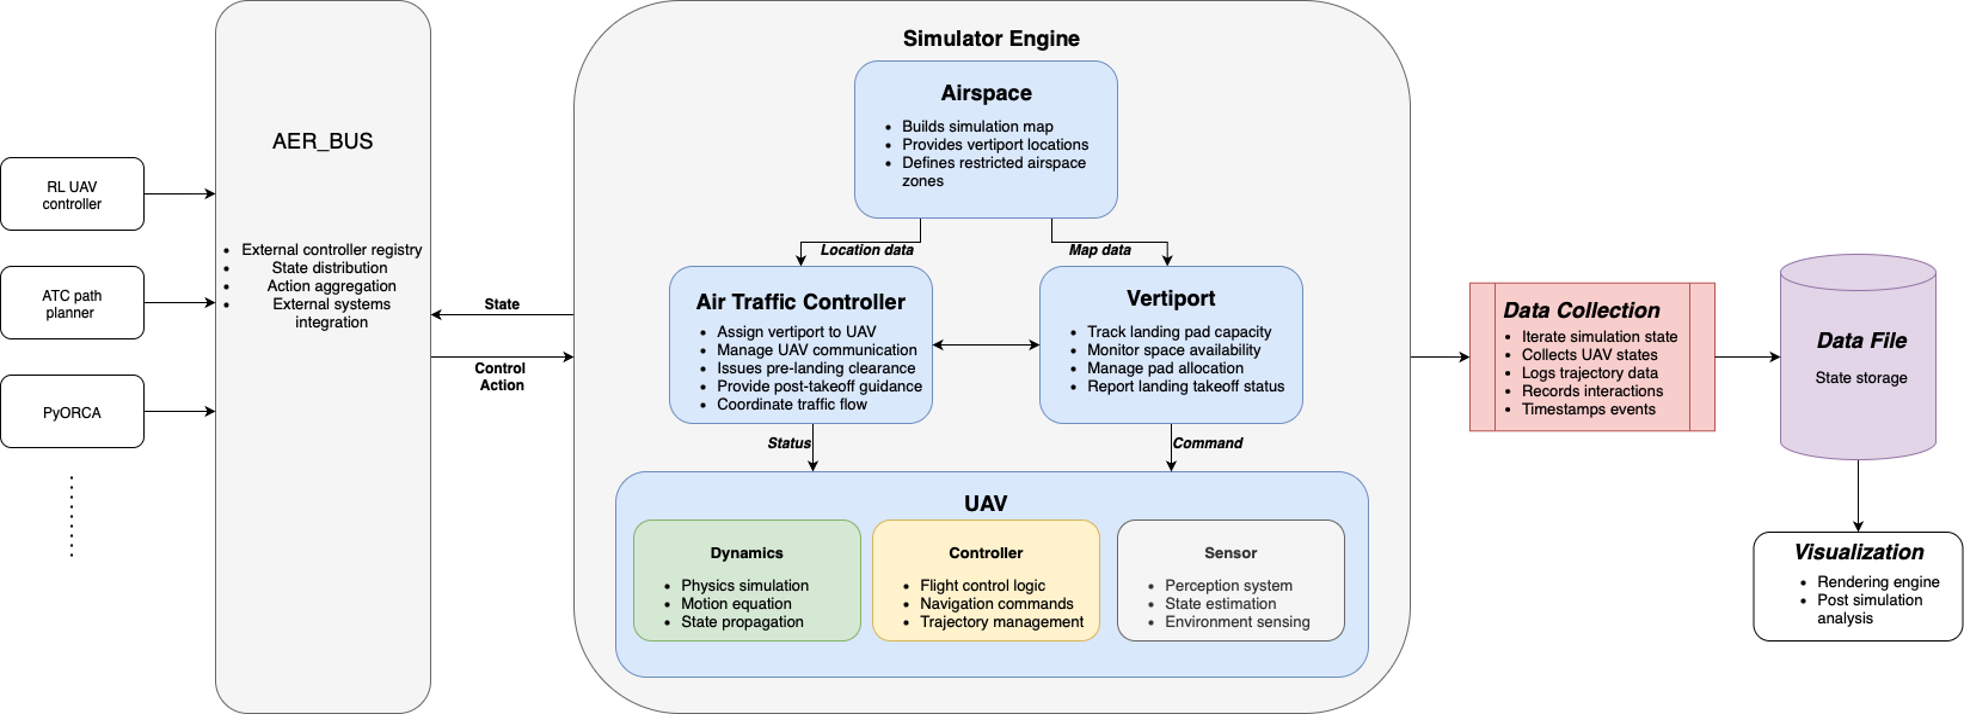
Urban Nav (IEEE Aerospace 2026) is a comprehensive simulation framework for urban air mobility research, built on a simulated skyline of Austin, Texas using Gymnasium. On top of it, we are developing deep-RL policies for multi-agent urban air vessel traversal, and, with graph-encoded multi-agent reinforcement learning (AIAA SciTech 2027, under review), conflict resolution that generalizes zero-shot to team sizes never seen in training.
This work is supported by a NASA Iowa Space Grant Consortium Undergraduate Research Scholarship and a Boeing Undergraduate Research Fellowship, under Dr. Cody Fleming at Iowa State's VRAC.